Build
November 13, 2026
Training a World Action Model (WAM) in NVIDIA Isaac Sim
Read blog
Read blog

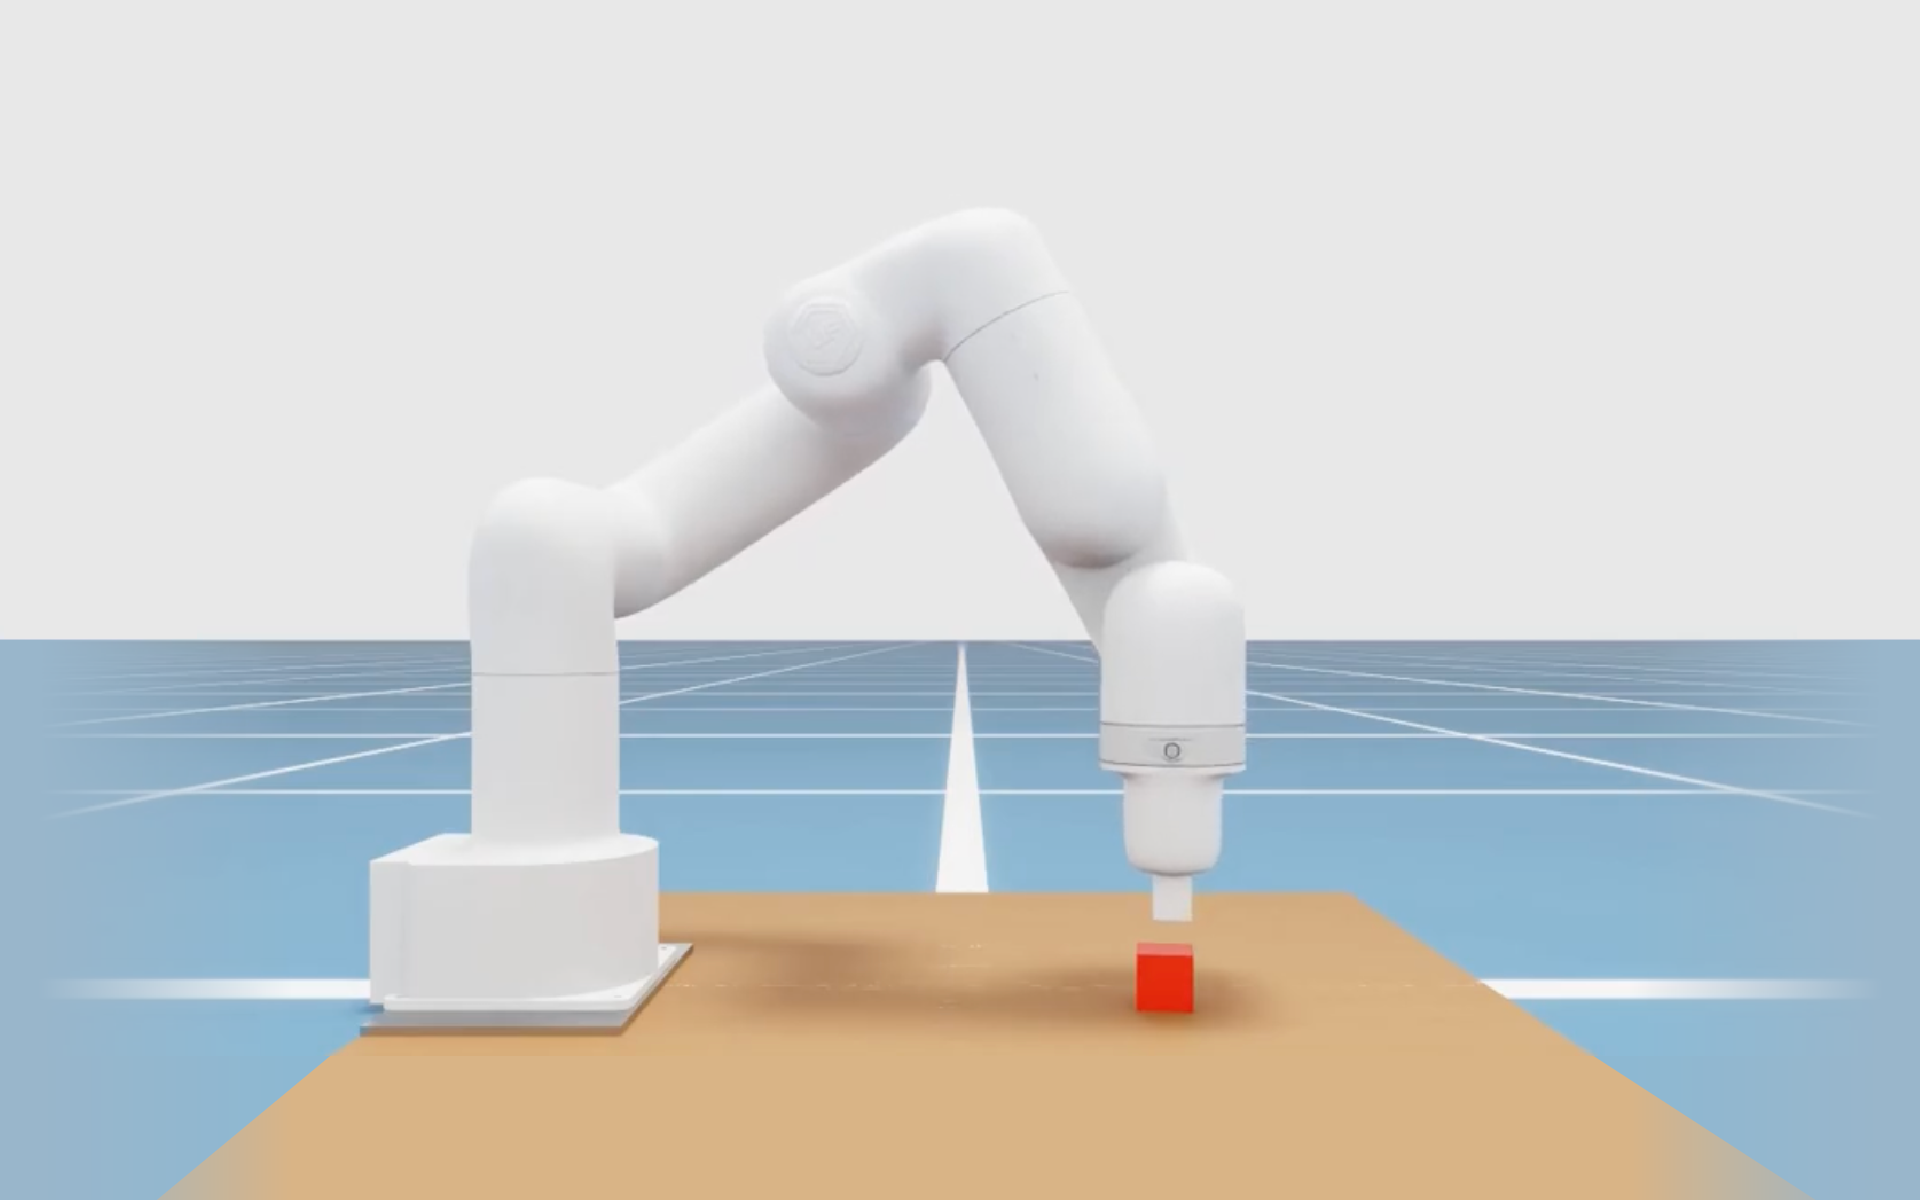
Training a motion policy is now accessible to every Viam user. Our new workcell-to-policy flow gives developers the ability to create a trained policy for an arbitrary robot task regardless of your previous ML experience, and without access to physical hardware.
VLAs and world action models are exciting to robot developers and system integrators because they promise to generalize complex tasks like manipulation and assembly, and because they’re increasingly sample-efficient, which reduces the expense of training them. Still, the barriers to getting started have kept them out of most developers’ hands: access to robots, a training set with video and robot poses, and the ability to attach to robot controllers on the inference side.
We’ve solved this by combining all these capabilities in a single platform. Our new workflow gives our users everything they need to create and test a motion policy: a simulated workcell, the ability to redesign it by hand or with frontier agents, a framework for episode capture, and the ability to deploy the trained policy back to the simulator for eval.
Our system guides users around the common pitfalls in policy creation by embedding our frameworks for task design and episode collection. Our agent integrations benefit from continuous improvement in the capabilities of frontier agents, including the leaps and bounds increase in spatial reasoning and robot control in Astra and Fable.
Over the last year we’ve been excited to watch our developer community pushing the limits of robot control with motion policies, and we’re excited to see what people create now that we’ve made these tools accessible to anyone with a laptop and a few hours.
Check out the webinar and tutorial to get started with these new capabilities, and ping us on discord to share your results and get help.